Professional
AutonomyROS 2
VDA5050 Support for Open-RMF
EIU × ARTC Singapore — Technical Lead
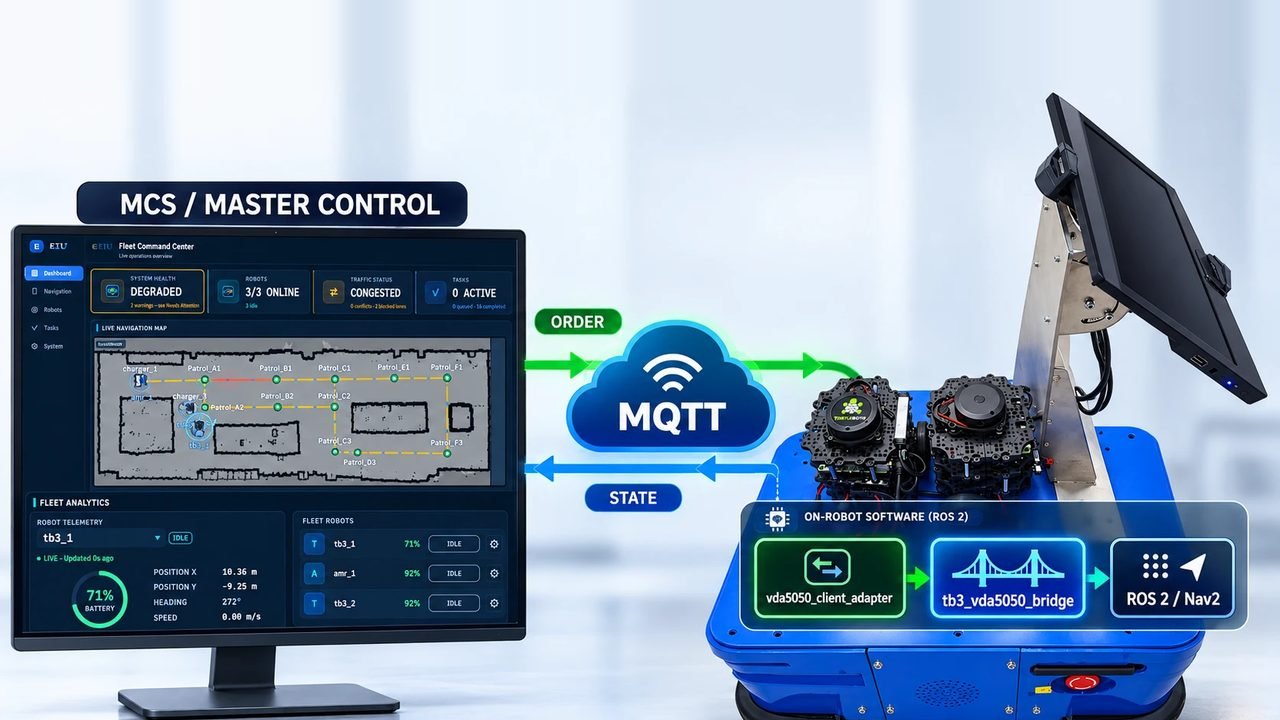
A ROS 2 Jazzy implementation of the VDA5050 v2.1.0 protocol that connects Open-RMF to a TurtleBot3 fleet and a custom FabLab AMR over MQTT — fleet adapters, a robot-side client adapter with a Nav2 bridge, and a PySide6/QML fleet dashboard. Tested on real robots and in Gazebo.