Projects

Selected projects from my professional work and personal research.

Professional Projects 10

Projects from my work at the EIU FabLab.

Professional
AutonomyROS 2Open-RMFVDA5050MQTTNav2Docker

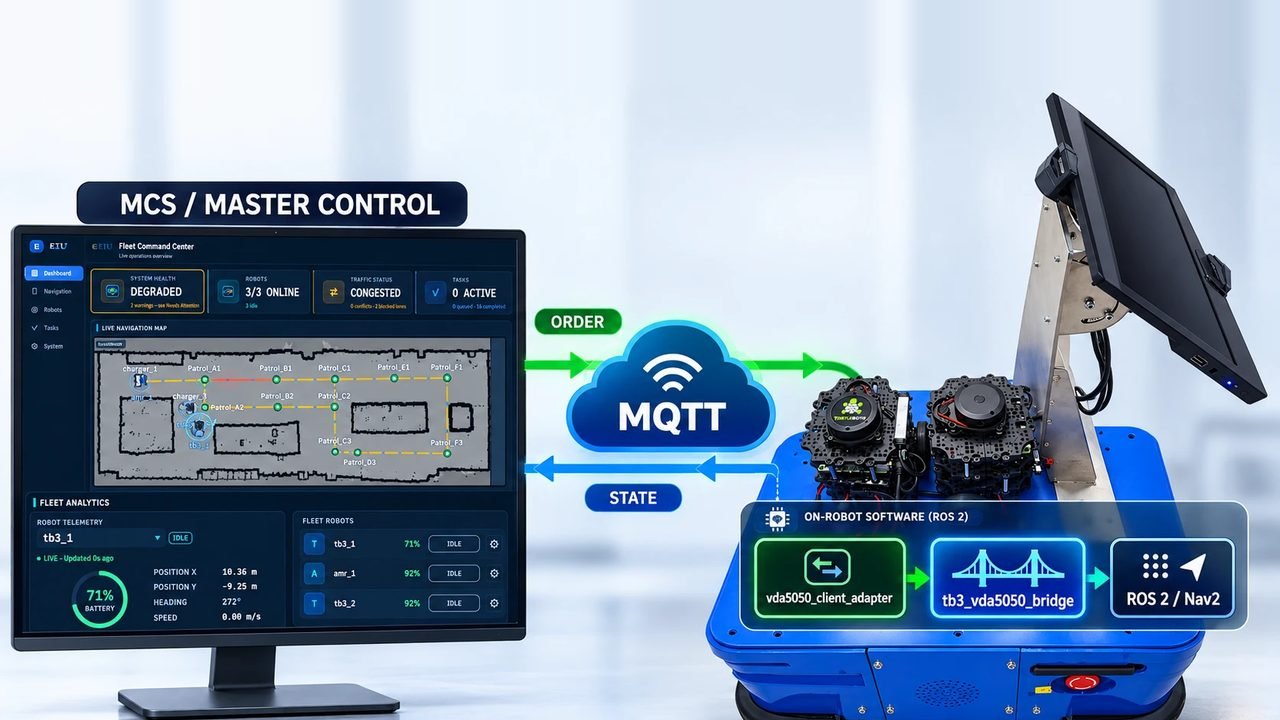
VDA5050 Support for Open-RMF

EIU × ARTC Singapore — Technical Lead
Jun 2026 – Nov 2026

A ROS 2 Jazzy implementation of the VDA5050 v2.1.0 protocol that connects Open-RMF to a TurtleBot3 fleet and a custom FabLab AMR over MQTT — fleet adapters, a robot-side client adapter with a Nav2 bridge, and a PySide6/QML fleet dashboard. Tested on real robots and in Gazebo.
Professional
AutonomyROS 2Nav2Visual SLAMComputer Vision

Autonomous Mobile Robot

EIU FabLab

Autonomous ground robot running ROS 2 with Visual SLAM, computer-vision perception and autonomous navigation (Nav2), on top of custom low-level firmware.

Professional
AutonomyROS 2Computer VisionEmbedded

Autonomous Drone

EIU FabLab

Autonomous drone platform integrating onboard computer vision and ROS 2 with the embedded flight hardware.

Professional
Embedded & HardwareRTOSCAN busModbusEthernetSPI / I2C / UART

Robot Low-Level Firmware

EIU FabLab

Firmware for robot controller boards on RTOS: peripheral drivers (SPI, I2C, UART) and CAN bus, Ethernet and Modbus communication, bridging sensors and actuators to the ROS 2 system.

Professional
Teaching & MentoringUAVArUcoComputer VisionMentoring

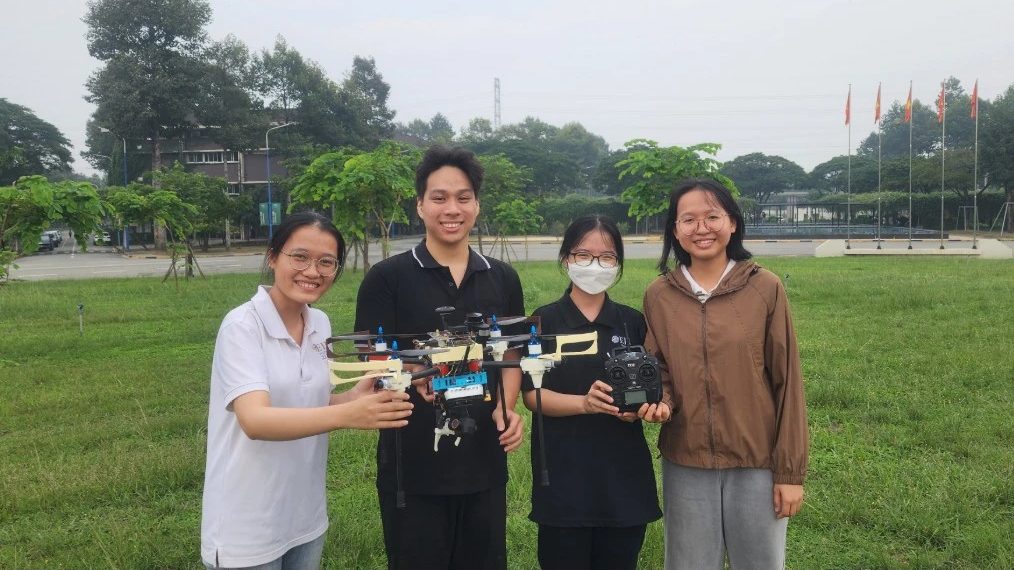
EIU-Spark Delivery UAV

EIU FabLab — mentor of team EIU-Spark
2026 – Ongoing (competition: October 2026)

Mentoring team EIU-Spark at the Ho Chi Minh City Youth UAV-Drone Creativity and Control Competition 2026 (October 2026). The delivery drone flies semi-autonomously from the start point to a pickup station, identifies the parcel by its ArUco marker, picks it up and carries it to the drop-off point. In progress — details coming soon.

Professional
Teaching & MentoringMentoringAutonomous VehiclesCompetition

AUTO RACE 2025 — Student Teams

EIU FabLab
2025

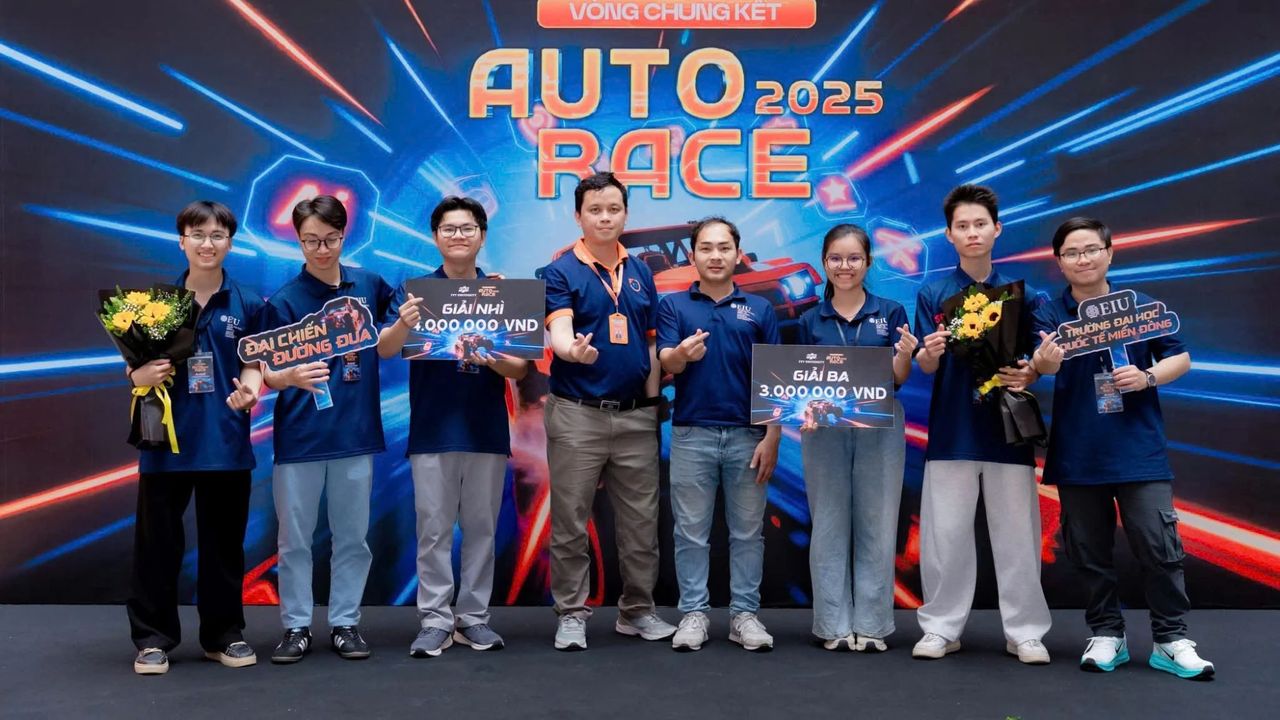
Mentored two EIU student teams at AUTO RACE 2025, the Southern Vietnam autonomous vehicle competition hosted by FPT University Can Tho — the teams won 2nd Prize and 3rd Prize.

Professional
Teaching & MentoringAEBKalman FilterAutonomous RacingResearch

Student Research — Best Paper Award (Student Session), EIUSC 2025

EIU FabLab — research mentor & co-author
Dec 2025

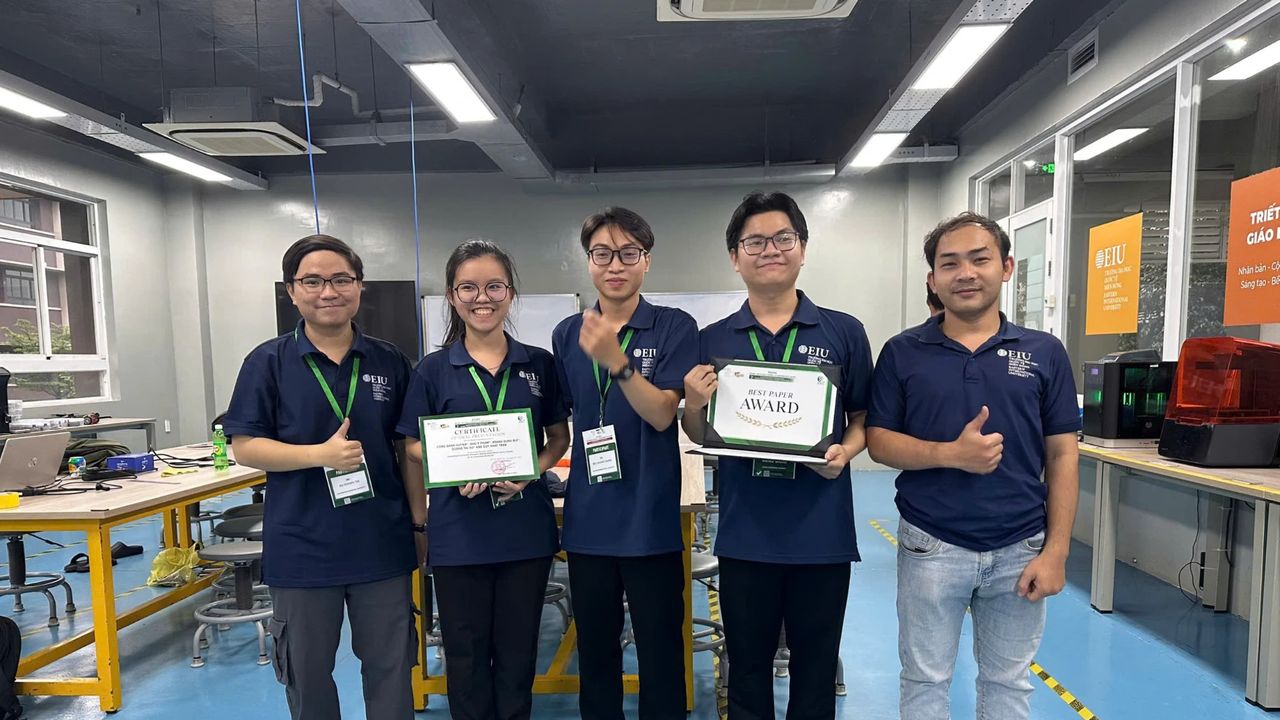
Mentored an EIU student team on the paper “Developing An Autonomous Emergency Braking System-Based Kalman Filtering For An Autonomous Racing Car”, presented at the EIUSC International Conference 2025 (Ho Chi Minh City, 3 December 2025) — it received the Best Paper Award (Student Session).

Professional
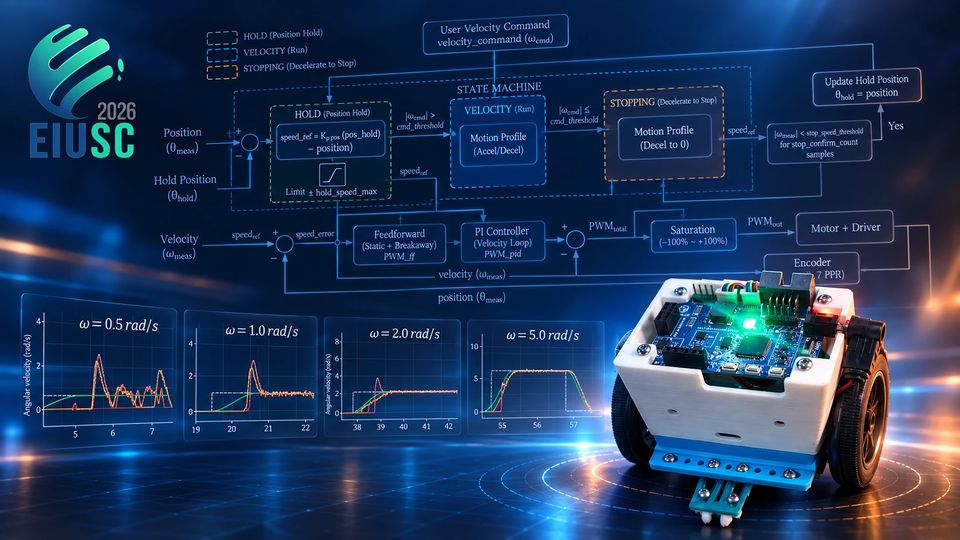
Embedded & HardwareMotor ControlPI ControlFeedforwardEmbedded

Feedforward-Assisted PI Speed Control for Geared DC Motors

EIU FabLab — research mentor & co-author
2026 — under review at EIUSC 2026

Student research paper (co-authored, under review at the EIUSC International Conference 2026): “Data-Driven Feedforward-Assisted PI Speed Control with Automatic Position Holding for Geared DC Motors”.

Professional
Perception & AIImitation LearningSim-to-RealControl Barrier FunctionsAutonomous Racing

Sim-to-Real End-to-End Autonomous Racing

EIU FabLab — research mentor (supervising author)
2026 — under review at EIUSC 2026

Supervised a student team on the paper “Sim-to-Real Transfer for End-to-End Autonomous Racing via Imitation Learning and Control Barrier Function Safety Filtering” (under review at the EIUSC International Conference 2026).

Professional
Teaching & MentoringSTM32F1TENTHROS 2DronesEmbedded

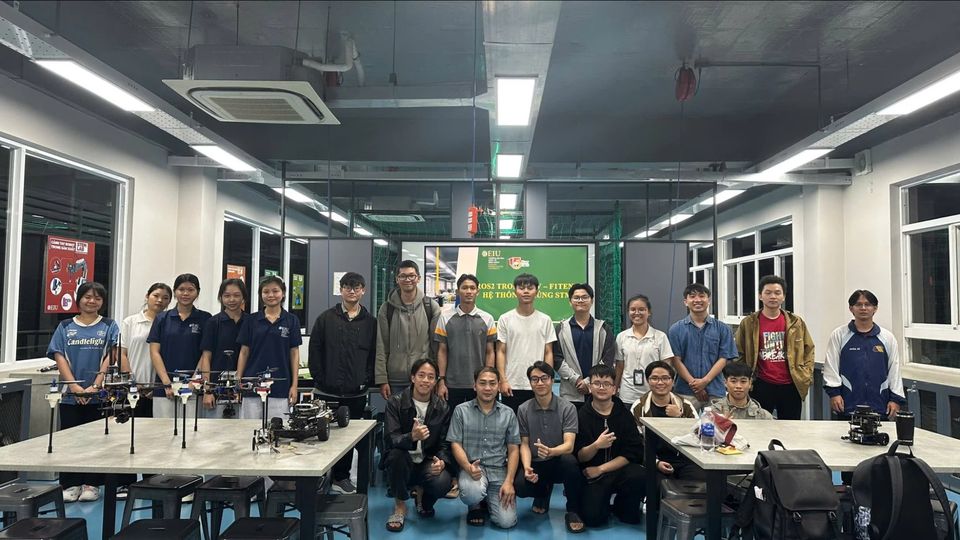
Weekly Robotics Workshop Series

EIU FabLab
Jan 2025 – Present

Organize and teach weekly hands-on workshops for students on robotics, ROS 2, drones and embedded systems — e.g. STM32 And Two-Wheeled Self-Balancing Robot (STM32 peripherals, IMU, EKF, LQR) and F1TENTH Autonomous Racing (ROS 2, SLAM, AMCL, Pure Pursuit, RRT*).

Personal Projects 2

Research, side projects and open-source work done in my own time.

Personal Terrain Segmentation on Jetson
Perception & AIPyTorchTensorRTJetsonSegmentation

Terrain Segmentation on Jetson

2021 – 2022

Lightweight segmentation network for terrain classification, optimized with TensorRT for real-time on-board inference on NVIDIA Jetson.

Personal Visual-Inertial Odometry
AutonomyC++CUDAVIOSLAM

Visual-Inertial Odometry

2023

Real-time visual-inertial odometry at 30 Hz on Jetson Orin with a sliding-window optimizer.